
Copper Runtime & SDK
A Rust runtime for building, running, recording, and deterministically replaying static robot task graphs, from Linux to bare metal.


▶ Try Copper in your browser · Build your first app
Why Copper
| Built for robots | Built to ship |
|---|---|
| Static by design: task graphs are declared in RON and wired at compile time. | Runs anywhere: Linux, macOS, SBCs, and bare-metal microcontrollers. |
| Realtime first: zero-allocation, data-oriented execution on the hot path. | Deterministic replay: record a run, reproduce it, and inspect it offline. |
| Rust-first: ergonomic task APIs with compile-time guarantees. | Interoperable: connect to ROS 2 through Zenoh and migrate progressively. |
Already flying, driving, swimming, spacefaring, and powering humanoids.
See It Run
These are the same Copper applications used on physical robots, recompiled for the browser. The simulator runs beside a live view of the Copper task graph and latency.
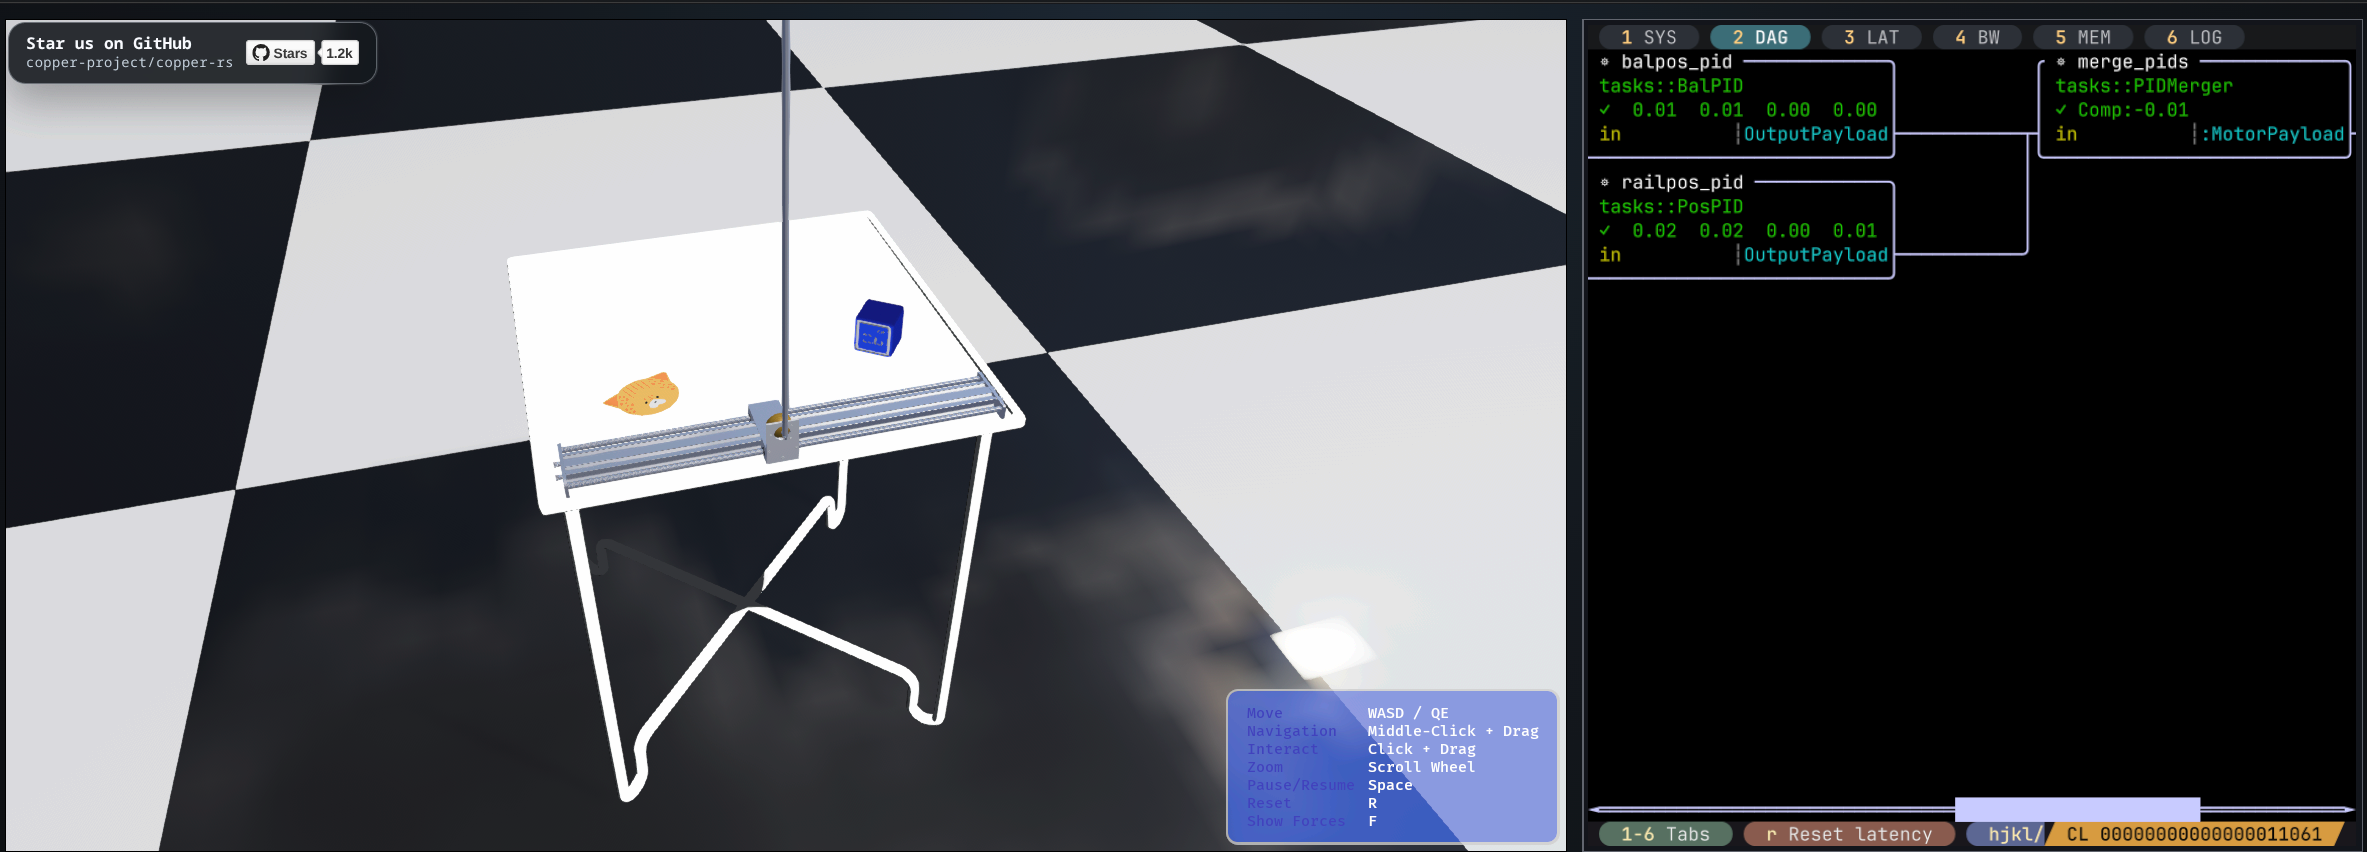
BalanceBot A self-balancing robot simulation using the application that runs on Raspberry Pi hardware. Source code |
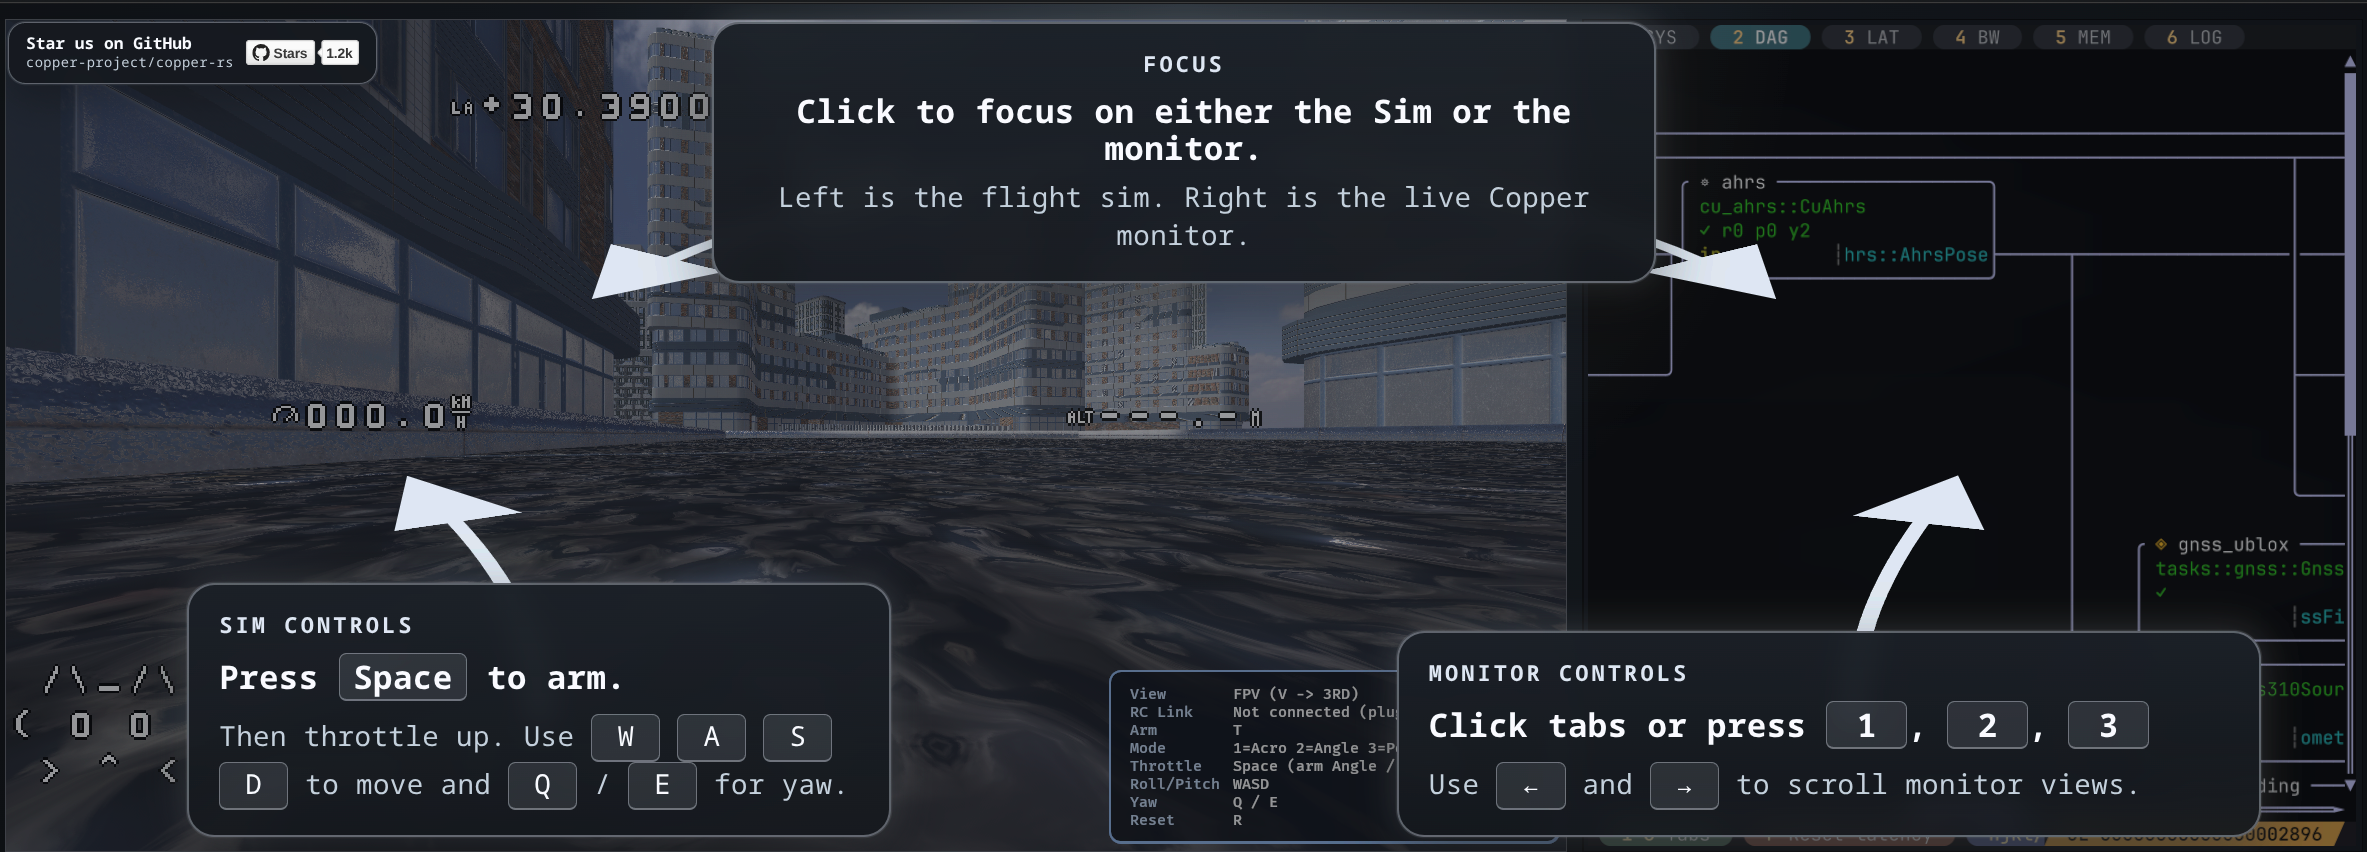
Flight Controller A quadcopter simulation using the control stack deployed on STM32H7 flight hardware. Source code |
Watch more robots built with Copper in the community showcase, or explore the cross-framework benchmarks.
Build Your First Copper App
Install the latest stable Rust toolchain, then:
cargo install cargo-cunew
cargo cunew hello_copper
cd hello_copper
cargo run
In about 30 seconds, you have a typed source → task → sink graph that prints its
first messages and records logs/hello-copper.copper. Start with
copperconfig.ron, src/main.rs, and src/tasks.rs; the generated justfile
also provides helpers for logs, CopperLists, topology (just graph), the exact
generated process schedule (just sched), post-execution timing from the default
Copper log (just sched-log), and replay. Host projects also include
just pgs-baseline, just pgs-optimize, just pgs-candidate, and
just pgs-measure; the starter schedule.ron is a conservative placeholder to tune
for the real workload. Project creation asks whether the target is bare metal/no_std
and omits PGS scaffolding for that choice.
How Copper Fits Together
| Stage | What happens |
|---|---|
| Declare | Define the static task graph in copperconfig.ron. |
| Generate | #[copper_runtime] wires the graph at compile time. |
| Run | Execute deterministically with a zero-allocation hot path. |
| Record | Capture messages, timing, and state in a unified .copper log. |
| Inspect | Replay a recorded run, export its data, and inspect its state. |
The robot is a static thing: Copper turns its declared graph into a purpose-built runtime, then records messages, timing, and state into one replayable log.
Live telemetry: stream robot data and structured logs to a ground station over
UDP, view live task outputs, and save a replayable .copper archive. A live Copper
twin can reconstruct selected deterministic task outputs locally to reduce
bandwidth. Try the telemetry demo.
Explore Copper
| Learn | Book · Runtime overview · API docs |
| Build | Project templates · RON reference · Component catalog |
| Go deeper | Examples · Logging and replay · Python support |
| Project | Supported platforms · Roadmap · Release notes |
| Community | Contributing · GitHub Discussions · Discord |